Raptor Pilot AI
Mission computer that sees at 60 FPS and decides on board, so nothing leaves the aircraft.
Platforms & flight systems
An ArduPilot flight controller with three IMUs from three makers, led by a tactical-grade ADIS16470, and direct power from a 5S–12S battery.
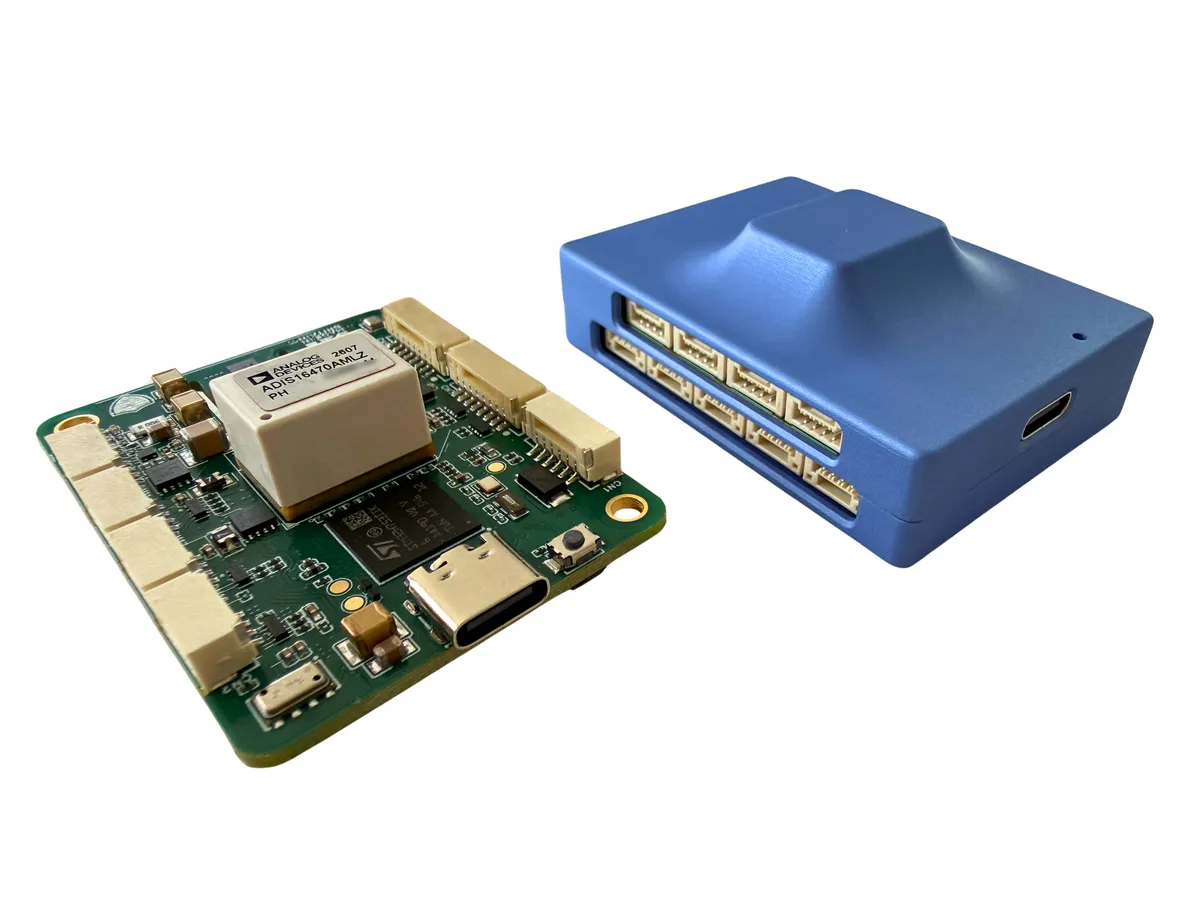
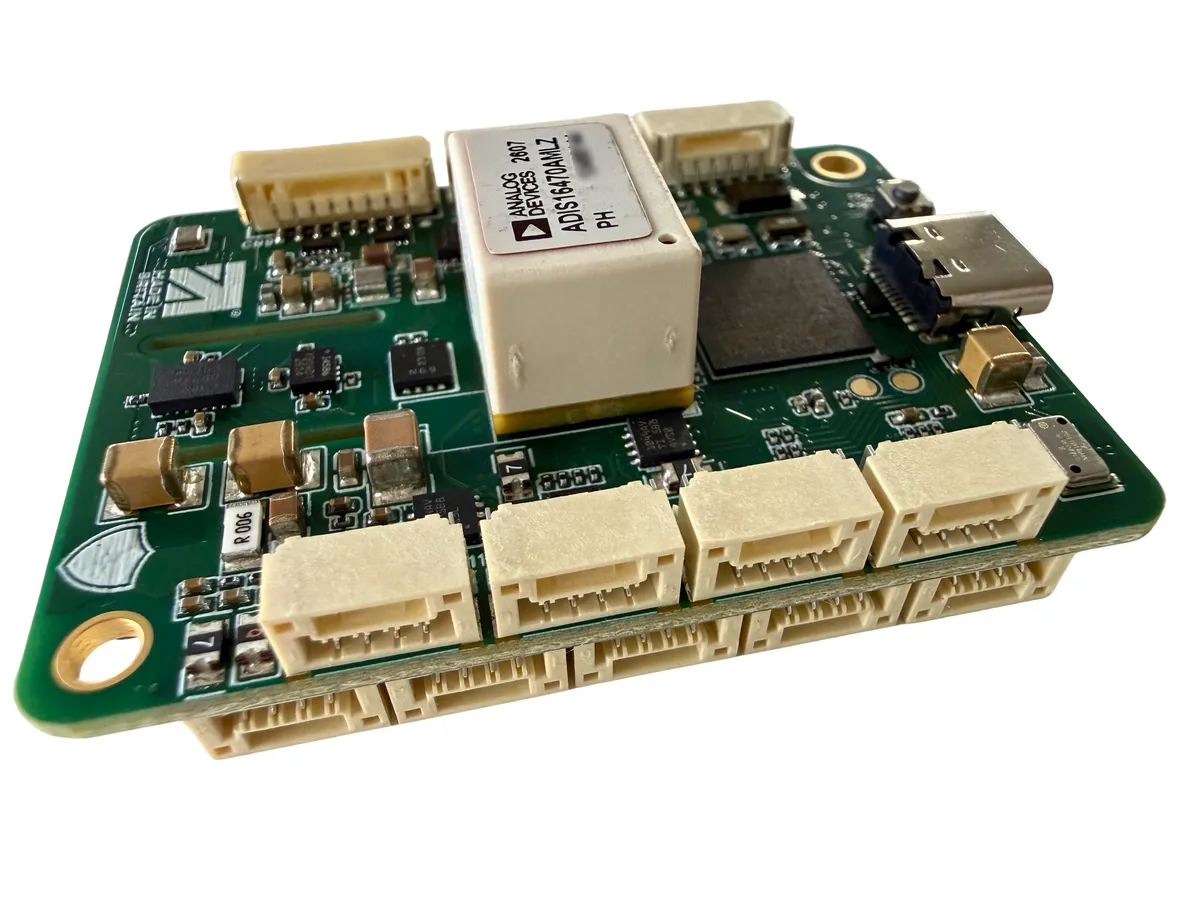
Raptor Pilot Pro FC is the flight controller we design for our own drones. It runs ArduPilot on an STM32H753 processor at 400 MHz, and its main sensor is a tactical-grade ADIS16470 IMU, factory calibrated from −10 to +75 °C.
It carries three IMUs from three makers: Analog Devices, TDK and Bosch. Each one has its own SPI bus and its own power supply, so a fault in one sensor cannot take the others down. ArduPilot EKF3 runs three lanes, one for each IMU. Two barometers on separate buses back each other up in the same way. The IMUs sit on a heated island, cut off from the rest of the board, so they work at a steady temperature.
Six full UARTs, two CAN FD buses, two I2C ports and eight PWM/DShot outputs connect it to the rest of the aircraft, all on JST-GH connectors. It takes power straight from a 5S–12S battery, and USB alone is enough for work on the bench. Every external port has ESD, PTC and eFuse protection. The board is 40 × 55 mm.
Specifications may change. We confirm the exact figures against the current datasheet when you ask.
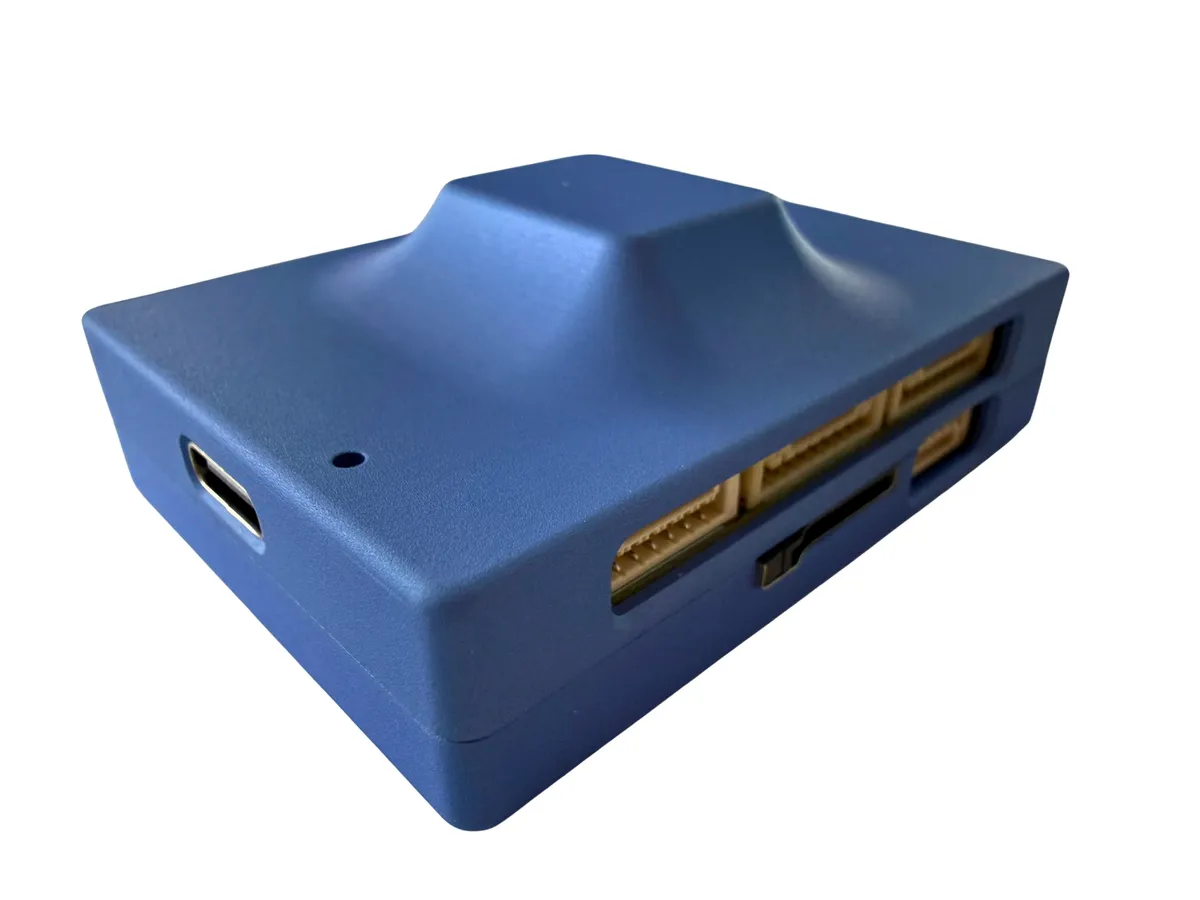
The unit from other angles.
More from the Raptor series.
Mission computer that sees at 60 FPS and decides on board, so nothing leaves the aircraft.
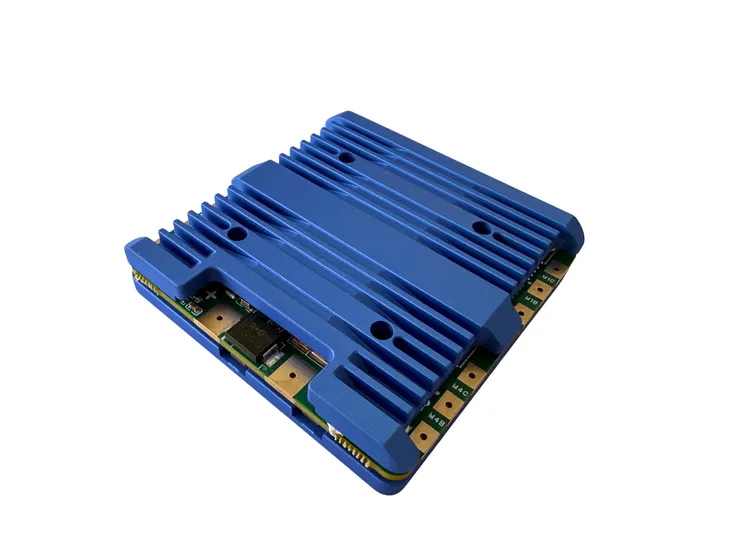
Four-in-one 6S–12S ESC with one processor per motor and full telemetry.
900 KV brushless motor for interceptors, up to 4.15 kg of thrust on 4S–12S.
Tell us what you need and we will show you how Raptor Pilot Pro FC fits, how it works with what you already run, and what a first step would look like.