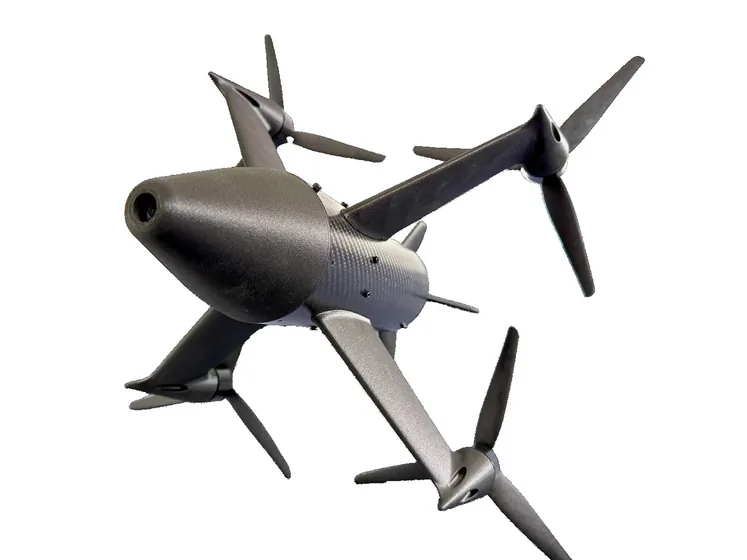
Baby Raptor Interception Drone
Small, fast interceptor that chases and stops hostile drones at up to 250 km/h.
Platforms & flight systems
The mission computer for drones and robots. It sees at 60 FPS and decides on board, so nothing has to leave the aircraft.
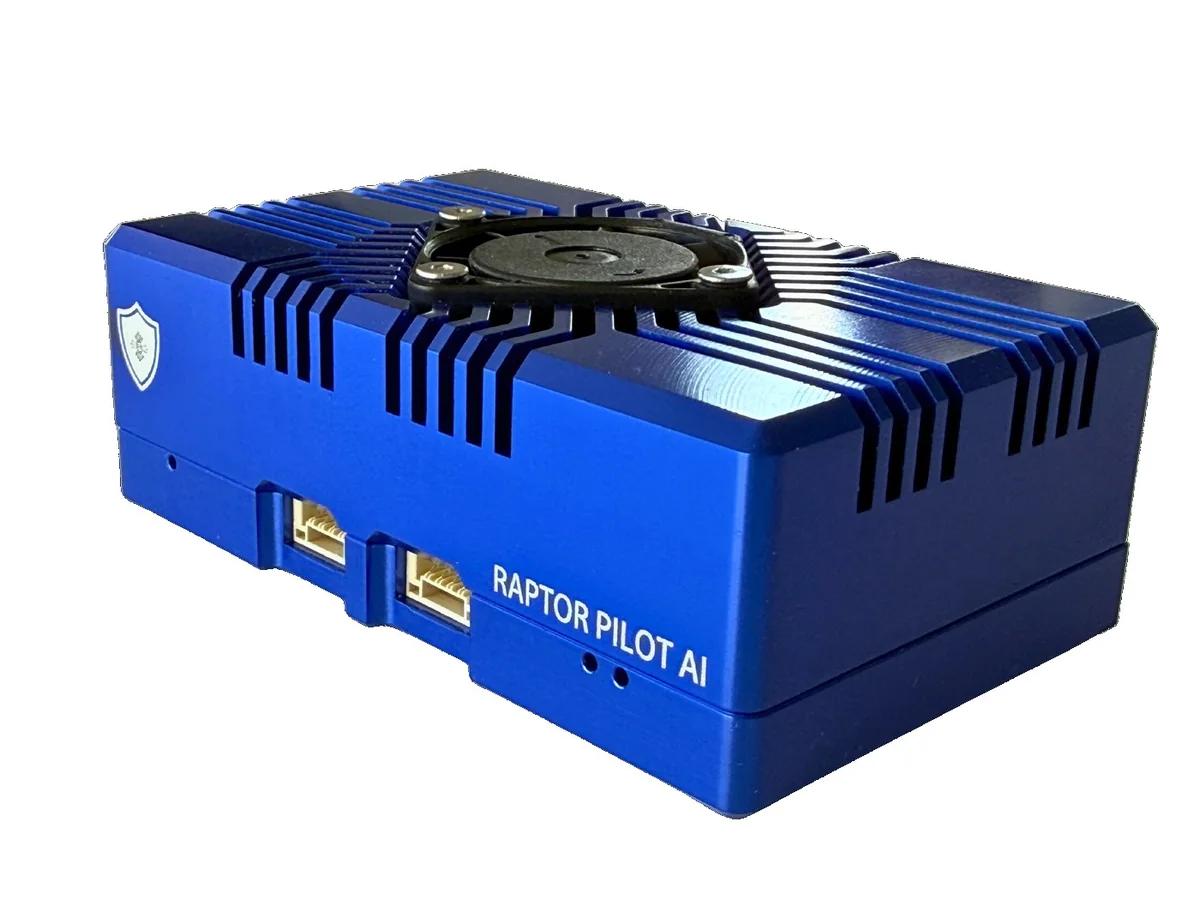
Raptor Pilot AI is the mission computer we build for drones and robots. Two digital cameras feed it straight in, so a wide view and a tracking view can run at the same time: one for the whole scene, one locked on the target.
A 4 TOPS AI chip runs detection and tracking next to a quad-core ARM64 processor with 16 GB of memory. There is no downlink, no cloud and no lag between seeing and acting. The aircraft decides for itself, and the video never has to leave it.
It runs Linux and common robotics software, so autonomy code you already have moves across without a rewrite. Gigabit Ethernet, UART and optional CAN connect it to flight controllers, gimbals and payloads, and it takes power straight from the main battery at up to 60 V. The whole unit is 72 × 44 × 25 mm and weighs 100 g, so it fits a small interceptor as easily as a large aircraft.
Specifications may change. We confirm the exact figures against the current datasheet when you ask.
Typical jobs this system is built for.
Guides an interceptor onto a moving drone in the last seconds of the run, when a radio link back to the operator is too slow to help.
Holds position and corrects drift by sight when GNSS is jammed or blocked, using the camera and the IMU together.
Keeps a moving subject in frame on the tracking camera while the wide camera watches the whole scene.
Guides the final approach onto a marked pad or a moving deck at sea, where a few centimetres matter.
Watches a fixed area and flags movement on board, so no video has to leave the aircraft.
Spots a person or a vehicle as it flies, so a find does not wait for a downlink or an operator to notice it.
Follows power lines and pipelines with the wide view for context and the tracking view locked on the fault.
Runs the same vision and autonomy on unmanned ground vehicles, not only on aircraft.
Follows a road or a vehicle from the air and reports what has changed since the last pass.
More from the Raptor series.
Small, fast interceptor that chases and stops hostile drones at up to 250 km/h.
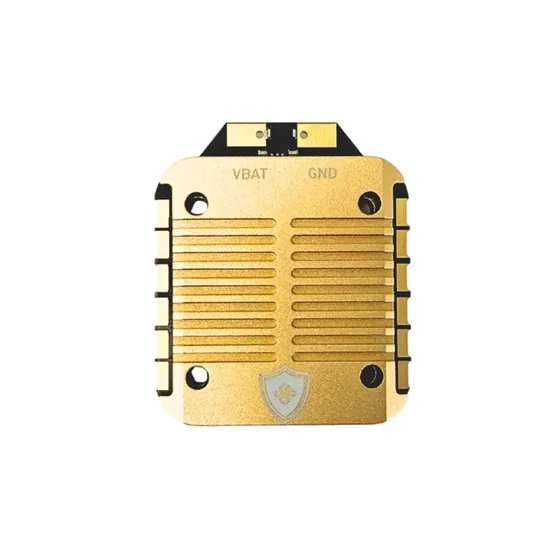
Four-in-one ESC giving 85 A per channel on 2S–8S, with built-in cooling.
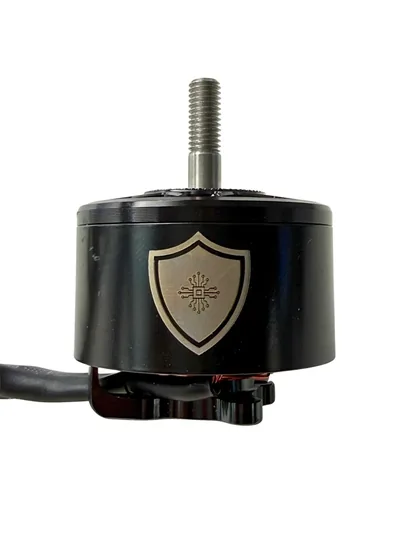
900 KV brushless motor for interceptors, up to 4.15 kg of thrust on 4S–12S.
Tell us what you need and we will show you how Raptor Pilot AI fits, how it works with what you already run, and what a first step would look like.